← Projects
Embedded softwareSystem architecture
Autonomous mobile robot
Complete ROS 2 architecture: drivers, perception, localization and navigation.
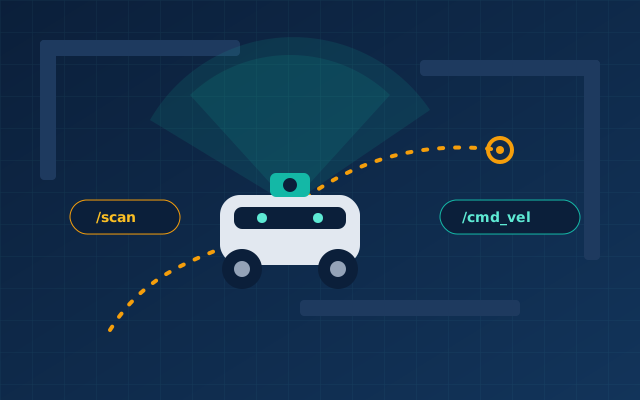
ROS 2modular architecture
SLAMmapping
Nav2autonomous navigation
The challenge
Make a mobile robot autonomous indoors with modular, testable software.
What I delivered
- Breakdown into ROS 2 nodes
- Mobile base driver in C++
- Lidar and IMU integration
- Mapping and navigation with Nav2
- Python monitoring tools
See also
Other projects
ElectronicsEmbedded software
Brushless motor controller
An ESC designed from scratch: power board, FOC firmware and test bench.
Industrial automation & roboticsProject management
Industrial robotic cell
Robot, PLC and safety systems integrated into a production cell.
Embedded softwareSystem architecture
This website, in Rust
Rust/Dioxus portfolio self-hosted on a Raspberry Pi, published at no cost.
Have a project in mind?
Let's talk about your needs, from idea to production.